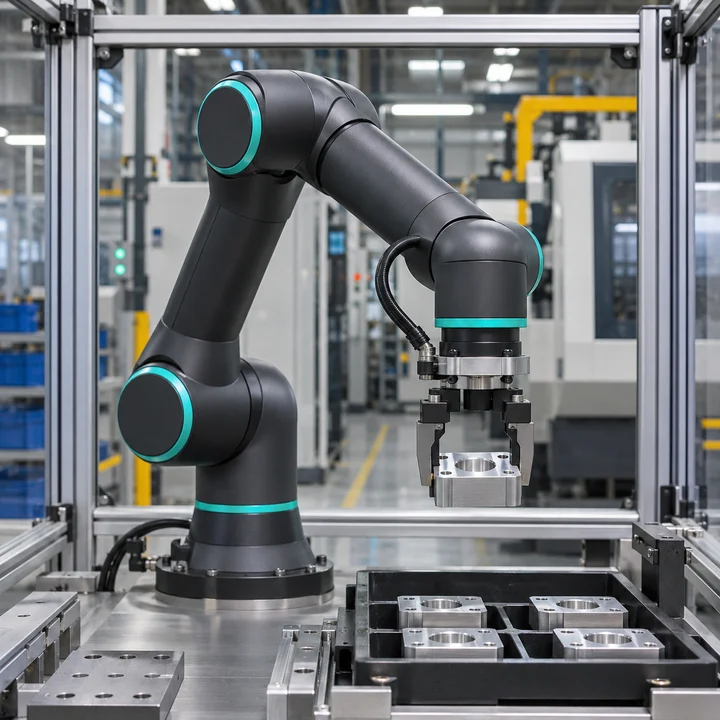
Frameless Motors for Collaborative Robot Joints
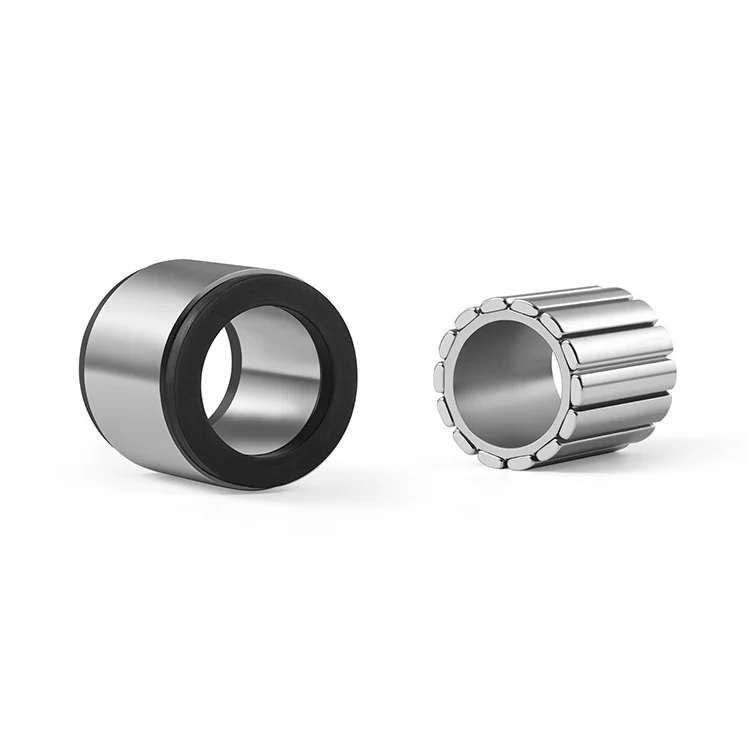
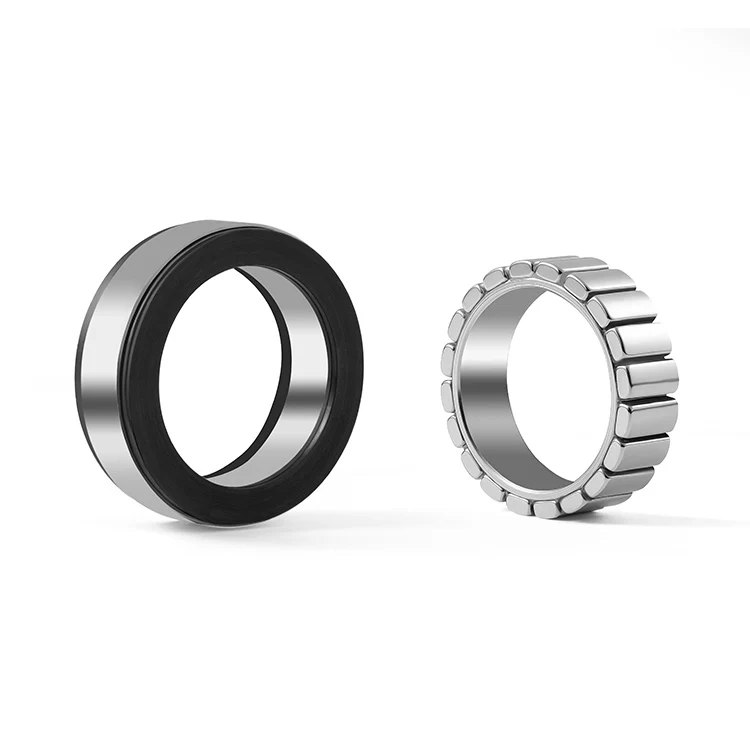
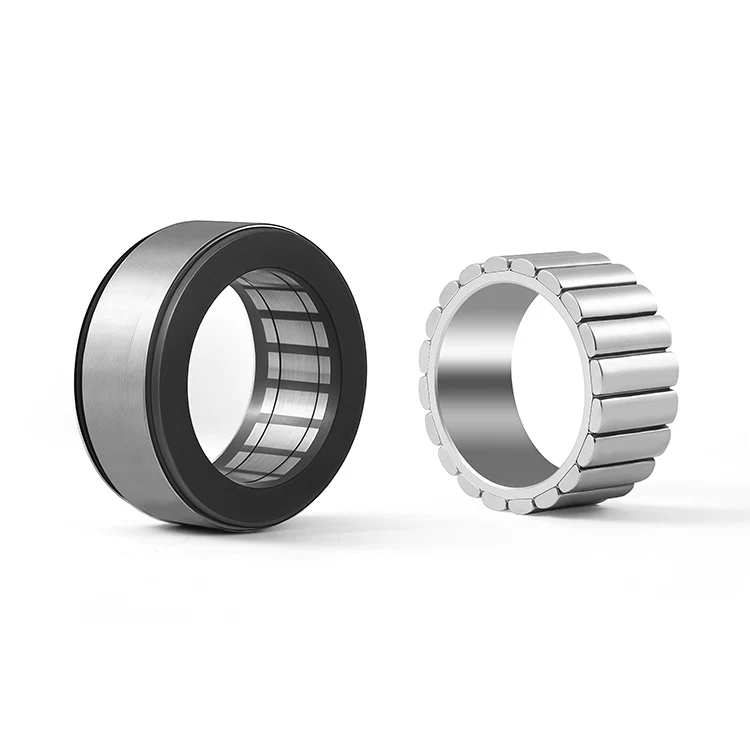
Collaborative robot joints need to deliver torque and move smoothly inside a compact arm. A frameless motor lets the joint structure serve as the motor housing, giving designers more room for the rest of the actuator.
Discuss Your ApplicationApplication Challenge
Each joint must fit a motor, bearings, feedback and wiring into a limited diameter and stack height. The actuator also needs enough continuous torque to handle repeated moves without overheating.
Motor Solution
A All Set Materials frameless torque motor places the stator inside the joint housing and connects the rotor to the shaft or reducer input. The motor can be selected around the joint envelope, torque and speed, with winding options reviewed against the available supply voltage.
Key Advantages
- Compact packaging. Integrating the motor into the joint can free axial space that a separate motor frame and mounting hardware would occupy.
- Flexible joint design. The same integration approach supports direct-drive and geared joints, depending on the torque and speed required.
- Fewer transmission interfaces in direct drive. Eliminating an intermediate coupling or gearbox can remove a source of backlash.
Technical Inquiry
All Set Materials can help compare motor sizes, review mounting drawings and discuss winding or mechanical customization. Share the joint diameter, available stack height, continuous and peak torque, speed, supply voltage and duty cycle.